Starterkit Quicksteps
The Starterkit STKa335x consisting of the TQMa335x module and MBa335x mainboard is intended as evaluation platform for the TQMa335x. To bring up the board a comprehensive set of accessories is supplied with the kit. The STKa335x is delivered preconfigured to boot the latest released Linux BSP revision at the time of delivery, so only the Host Computer has to be set up properly to bring the STKa335x up. This page guides through the first steps with the STKa335x Starterkit.
Setup Host Computer
Serial Driver
The TQMa335x debug UART is connected with an RS232 Transceiver to X15 on the MBa335x. An RS232 cable is part of the STKa335x accessory set.
Linux
The FTDI driver is maintained in the Linux mainline kernel, the configuration options below must be activated in the Linux kernel configuration to operate the USB-to-Serial converter
- CONFIG_USB_SERIAL
- CONFIG_USB_SERIAL_FTDI_SIO
Windows
The driver can be downloaded from the FTDI website:
https://ftdichip.com/drivers/vcp-drivers/
An installation guide can be found at the following link:
https://ftdichip.com/document/installation-guides/
Terminal Emulator
Linux
Minicom
Minicom is a command line based serial terminal for serial communication with hardware like our starterkits.
Install Minicom using APT(Debian/Ubuntu)
$ sudo apt install minicom
In order for the terminal to work properly with full rights you need to add your user to the dialout group:
$ sudo usermod -a -G dialout $USER
Connect Starterkit to Host
To determine the serial device name under linux you can use dmesg. Just run the command below and then plug in the starter kit to see the new detected interface names:
$ dmesg -w
Once the interface name is clear you can abort dmesg with ctrl + c.
Now you can start minicom via the command line interface:
$ minicom -D /dev/ttySx
Configure minicom
The serial configuration should be correct by default. However, hardware flow control must be disabled for some starter kits, otherwise the communication works only in one direction.
- Press CTRL + A, then press O to open the configuration menu
- Go to Serial port setup
- Press F to change Hardware Flow Control to No
- Hit Return key
- Select Save setup as dfl to save this configuration as default
- Press ESC to exit the menu
Now you should be able to communicate with the starter kit

Windows
TeraTerm
TeraTerm is an open source terminal emulator for windows. It can be downloaded here.
Configure TeraTerm
- Download and install TeraTerm
- Start TeraTerm and open the Serial Port Settings
- Select your serial port and configure it with the values defined in the chapter Serial Configuration
- After passing the values click on the button New Setting
Now TeraTerm should be ready for use with our starter kits.

Host PC Serial Port Configuration
The serial port which connects the STKa335x to the Host PC must be configured as follows:
| Baud rate: | 115200 |
|---|---|
| Data bits: | 8 |
| Parity: | none |
| Stop bits: | 1 |
| Handshake: | XON/XOFF |
Connecting the Starterkit to the Development Host
Please follow the quick start guide delivered with the kit, or open it from the following link: Quick start guide
Linux
BSP Login Credentials
As soon as logging in on the Linux shell for the first time, the question about the login credential comes up.
By default the user root is used to log into the Linux shell, no password is set for user root.
tqmaxx-mbaxx login: root
Testing Interfaces on STKa335x
To get familiar with the interfaces of the STKa335x we recommend to work through the interface tutorials first.
Building the BSP
The Board Support Packages provided by TQ may not contain all software packages to evaluate the STKa335x, therefore TQ provides some guides how to build the BSP and customize it for your needs:
In addition to the BSP documentation, the Yocto SDK build and Eclipse IDE setup for the STKa335x is also documented.
Setup Starterkit for different boot sources
The STKa335x can be setup to boot from different sources. Please see the DIP switch settings below to change the boot source.
Boot Device Selection (S2)
To select the desired boot order set the DIP switch S2 accordingly.
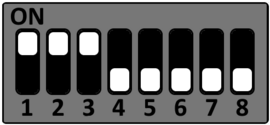
The following boot sequences of the AM335x can be selected by the DIP switch S2 on the MBa335x. Each boot device in a sequence will be searched until a valid boot image is found.
MMC0 (SD) → SPI0 (NOR) → UART0 (N/A) → USB0 (N/A)
S2
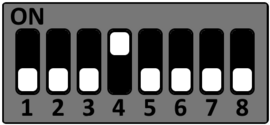
MMC1 (eMMC) → MMC0 (SD) → UART0 (N/A) → USB0 (N/A)
S2
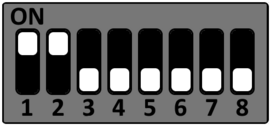
SPI0 (NOR) → MMC0 (SD) → USB0 (N/A) → UART0 (N/A)
S2
CPU oscillator frequency configuration (S1)
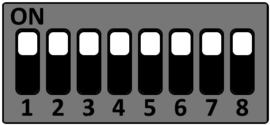
DIP switch S1-7 and S1-8 are used to configure the CPU oscillator frequency.
19.2 Mhz
S1
24 Mhz (default)
S1
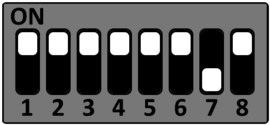
25 Mhz
S1
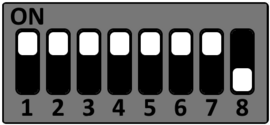
26 Mhz
S1
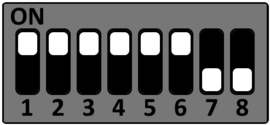
Functional DIP Switches
DIP-Switch settings for CAN and RS485.
CAN configuration (S3)
DIP switch S3 is used to configure the CAN interfaces CAN1 and CAN2.
| DIP | OFF (default) | ON |
|---|---|---|
| S3-1 | CAN1 not terminated | CAN1 interface terminated (120Ω) |
| S3-2 | CAN2 not terminated | CAN2 interface terminated (120Ω) |
RS485 configuration (S4)
DIP switch S4 is used to configure the RS485 interface.
| DIP | OFF (default) | ON |
|---|---|---|
| S4-1 | RS485 RxD not terminated | RS485 RxD terminated (120Ω) |
| S4-2 | RS485 TxD not terminated | RS485 TxD terminated (120Ω) |